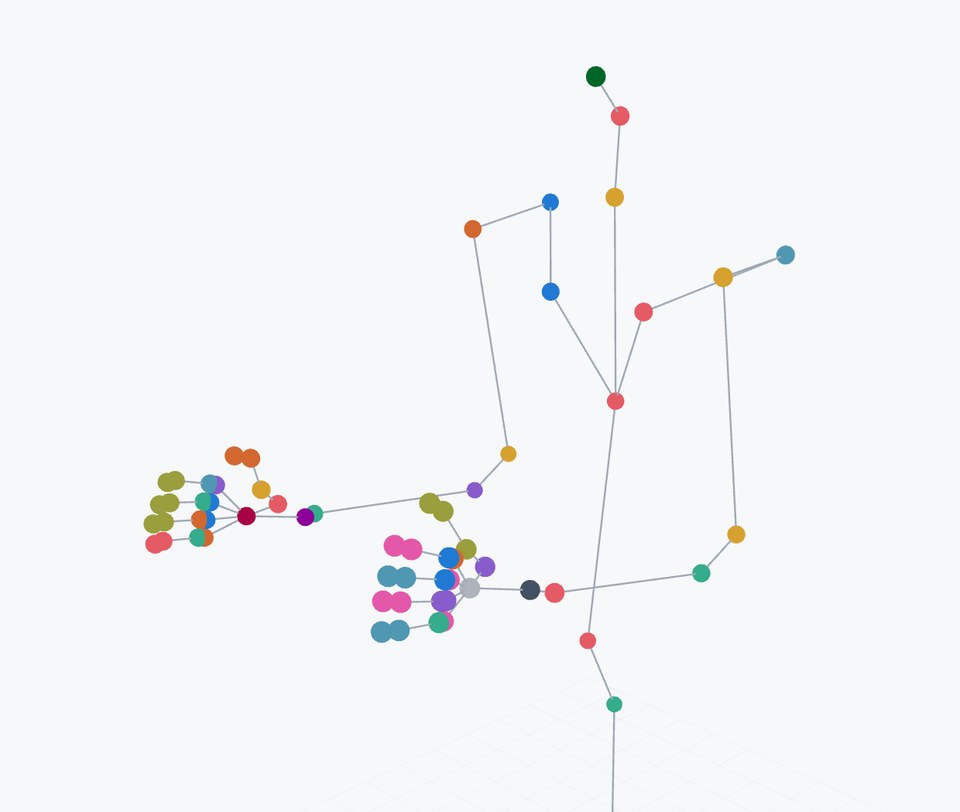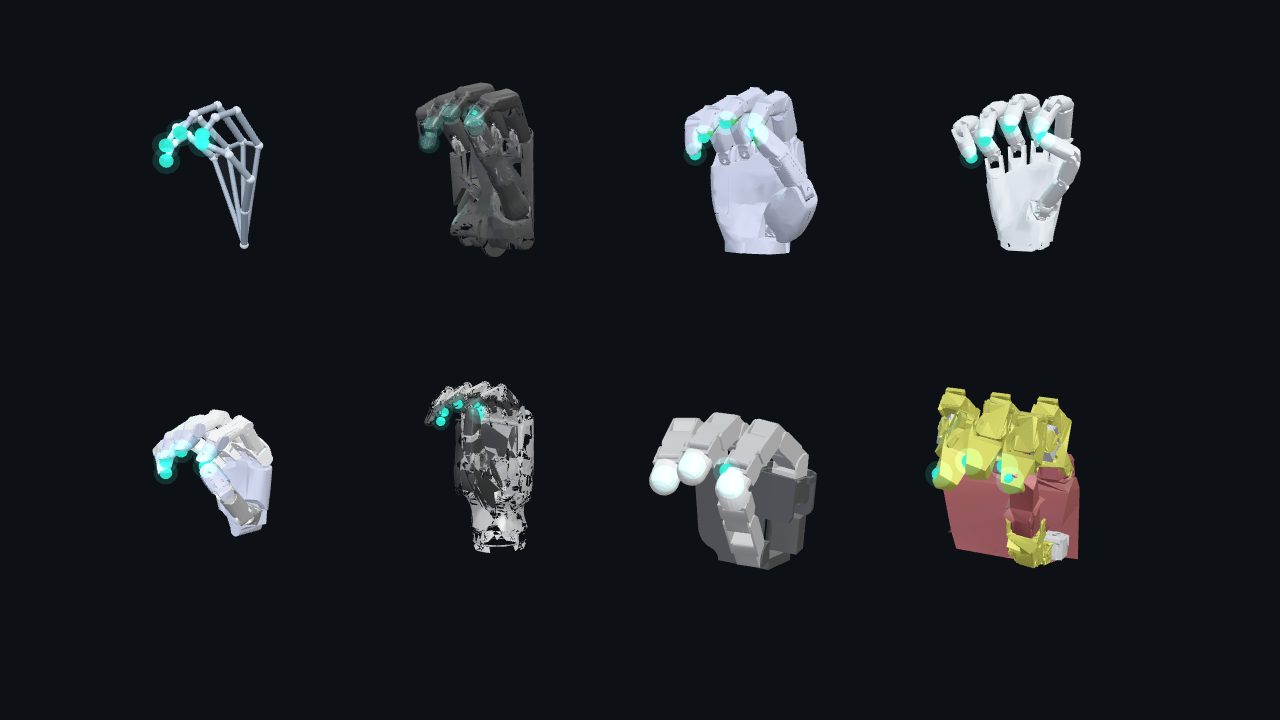
One Action Interface, Seven Dexterous Hands
Georgia Tech RL2, advised by Prof. Danfei Xu
[Project page]
Georgia Tech RL2, advised by Prof. Danfei Xu
[Project page]
Can a policy trained on several robot hands control a hand it has never seen?
I'm an M.S. Robotics student at Georgia Tech, advised by Prof. Danfei Xu in the Robot Learning and Reasoning Lab (RL2). I work on generalizable robot policies: from one dexterous hand to another, and from human demonstrations to robots.
Previously, I was a Research Engineer at RLWRLD, adapting robot foundation models to dexterous hands. Before that, I interned at Naver Labs and Seoul Robotics, and received my B.E. in Mechanical Engineering from The Cooper Union.
I'm looking for research internships for Summer 2027. Feel free to reach out!
 Aug 2026 – presentGeorgia Tech RL2Graduate Researcher, advised by Prof. Danfei Xu
 Apr – Aug 2026RLWRLDResearch Engineer
 Mar – Aug 2022Naver LabsDeep Learning Research Intern, Autonomous Driving
 May 2021 – Mar 2022Seoul RoboticsMachine Learning Research Engineer Intern
 May – Jul 2020Seoul National UniversityResearch Intern, Prof. Dongjun Lee
Can a policy trained on several robot hands control a hand it has never seen?
I built an Apple Vision Pro teleoperation setup for seven simulated robot hands and recorded 357 grasping demonstrations with it. On hardware, I teleoperate a Wuji Hand 2 with the Vision Pro to collect tactile data.
Policies trained only on egocentric human demonstrations, with no robot data, run zero-shot on a real RB-Y1 humanoid. Along the way I studied what makes retargeted demonstrations learnable.
At RLWRLD I worked on getting large pretrained policies (GR00T N1.6, π0.5, and a 3D geometry-aware policy) to work on DexJoCo, a public benchmark with 11 dexterous manipulation tasks.
GR00T N1.6 packs a humanoid's 48 joint values into a single token. Splitting them into 11 tokens raised simulated success from 35.8% to 41.5% without adding any parameters.
An end-to-end autonomous navigation stack (3D LiDAR SLAM, localization, planning, control) for an indoor delivery robot, with localization latency under 100 ms.
LiDAR- and RGB-based localization, mapping, and path planning in ROS, plus an OCR-based stop-sign classifier. Placed 2nd in autonomous navigation and 3rd in vehicle design.